Be Anywhere
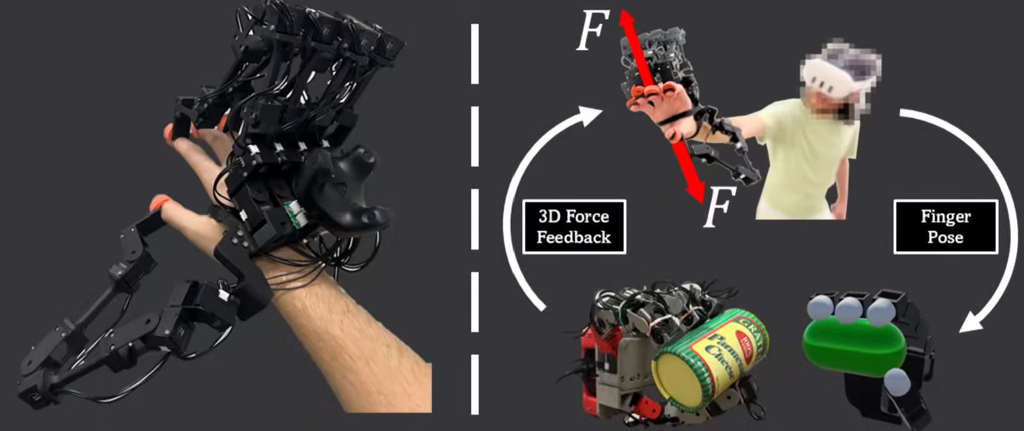
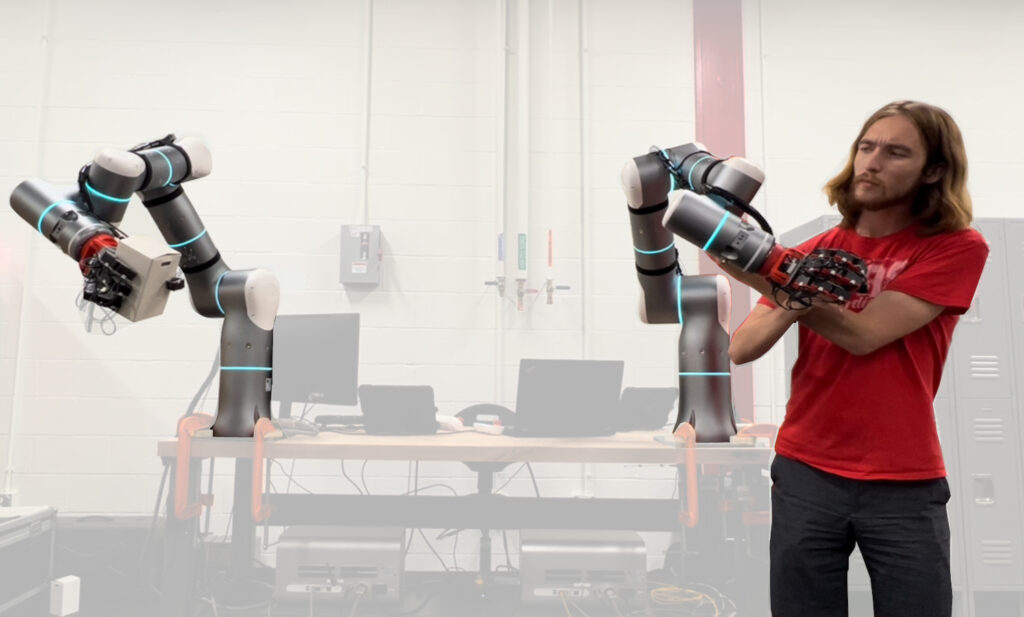
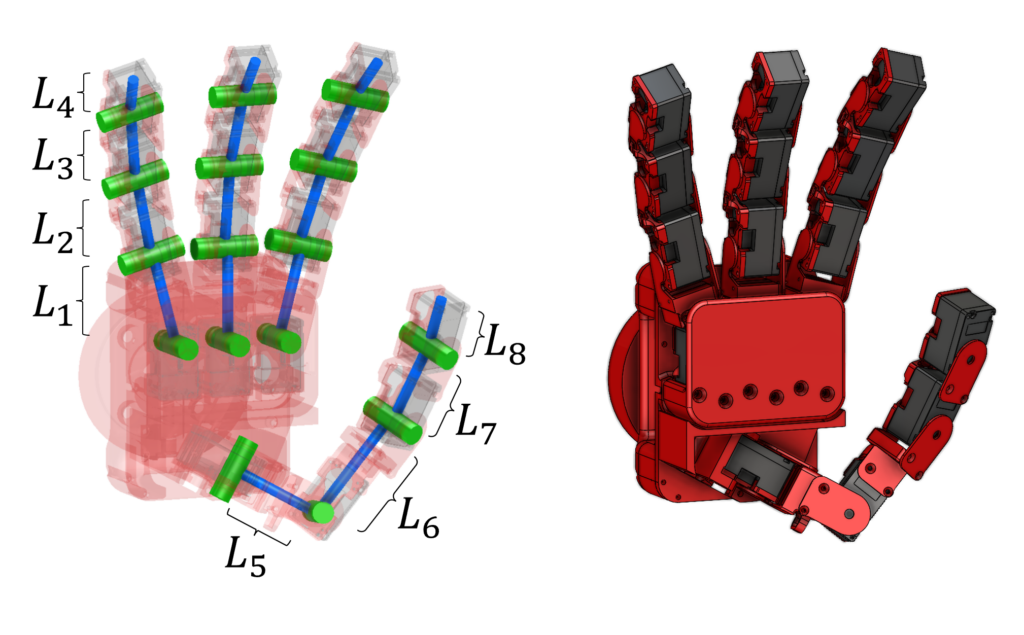
“APEX-Glove: An Actuated, Open-Source, Hand-Exoskeleton Glove for Finger Motion Tracking and Kinesthetic 3D Force Feedback,”
(ICRA 2026)
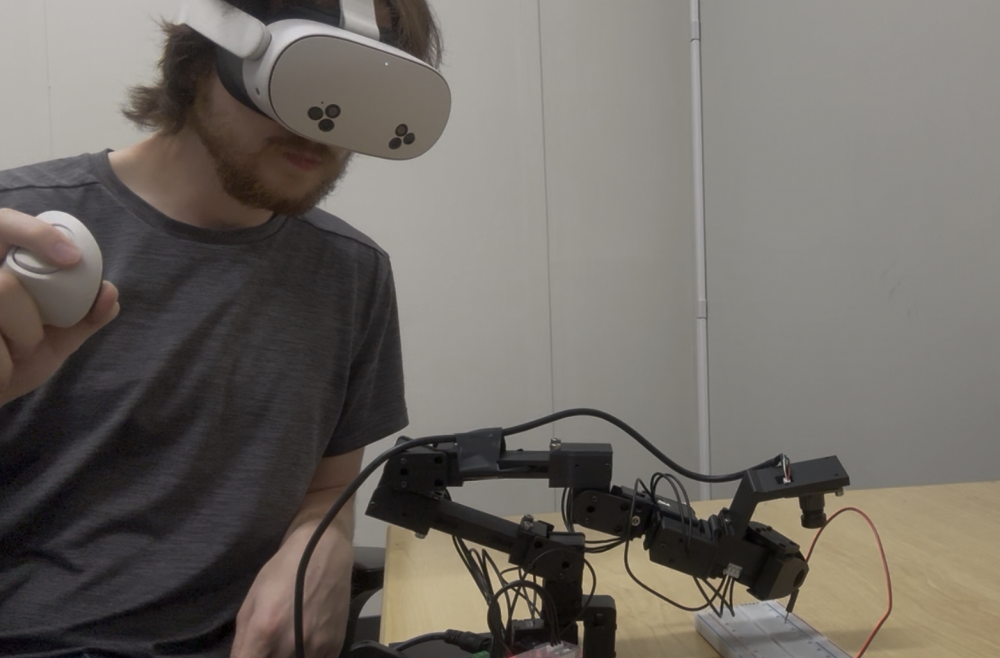
“Hardware Design of the 5 Degree of Freedom TinyARM5 Robot: Towards Open-Source Torque-Controlled Desktop Manipulation,”
(NAECON 2026)
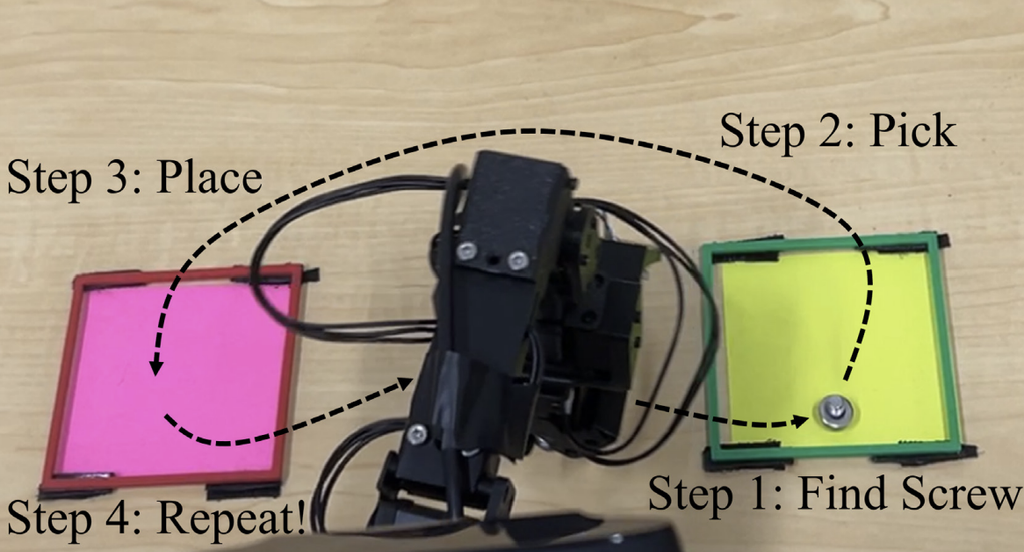
“Comparing Different Teleoperation Input Devices for Collecting and Evaluating Robotic Imitation Learning Policies,”
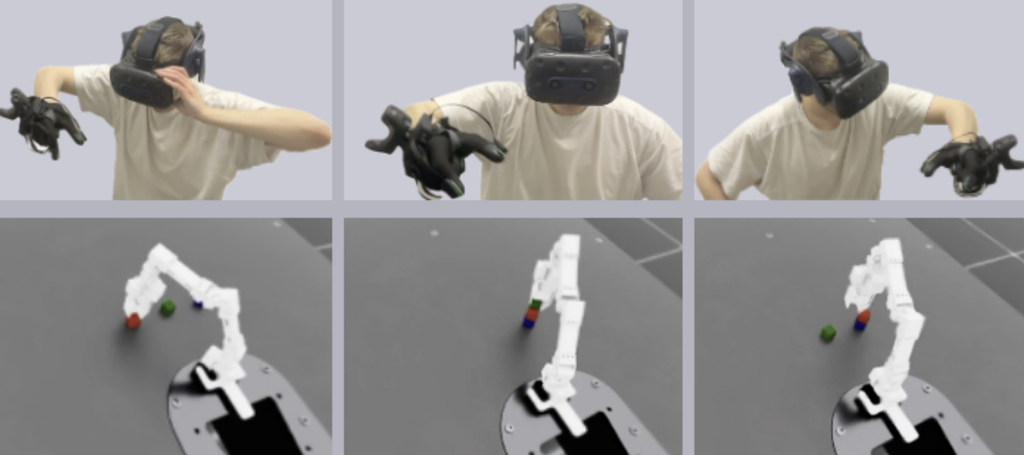
“Learning to Stack: Cube-Stacking Imitation Learning from Virtual Reality Demonstrations,“
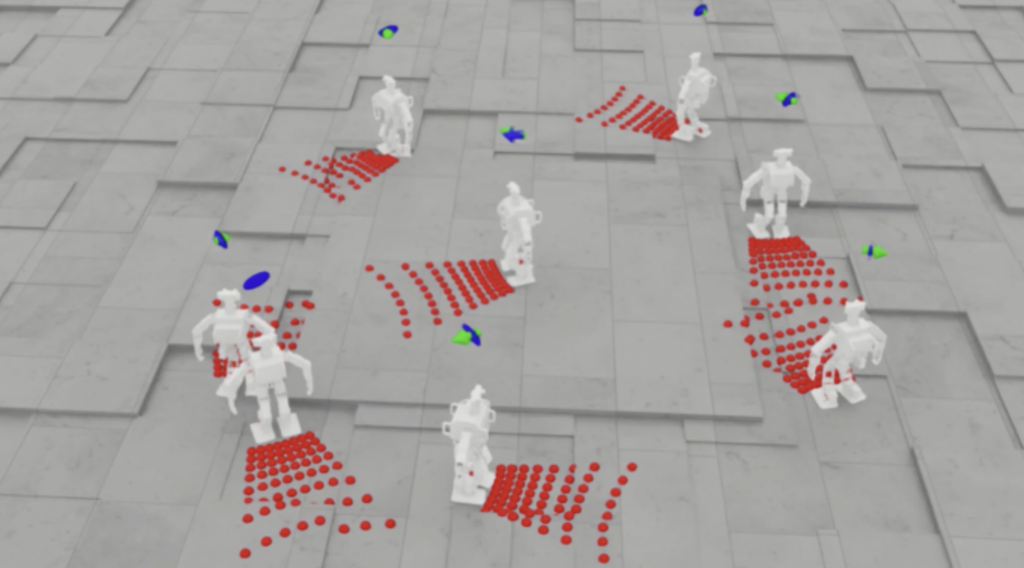
“Loco-Loco-RL: Low-Cost Terrain Mapping for Humanoid Locomotion with Reinforcement Learning“
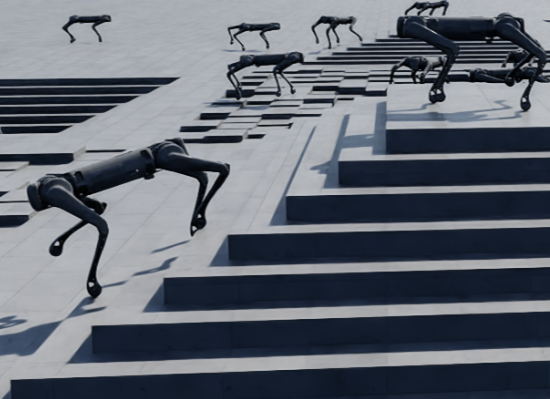
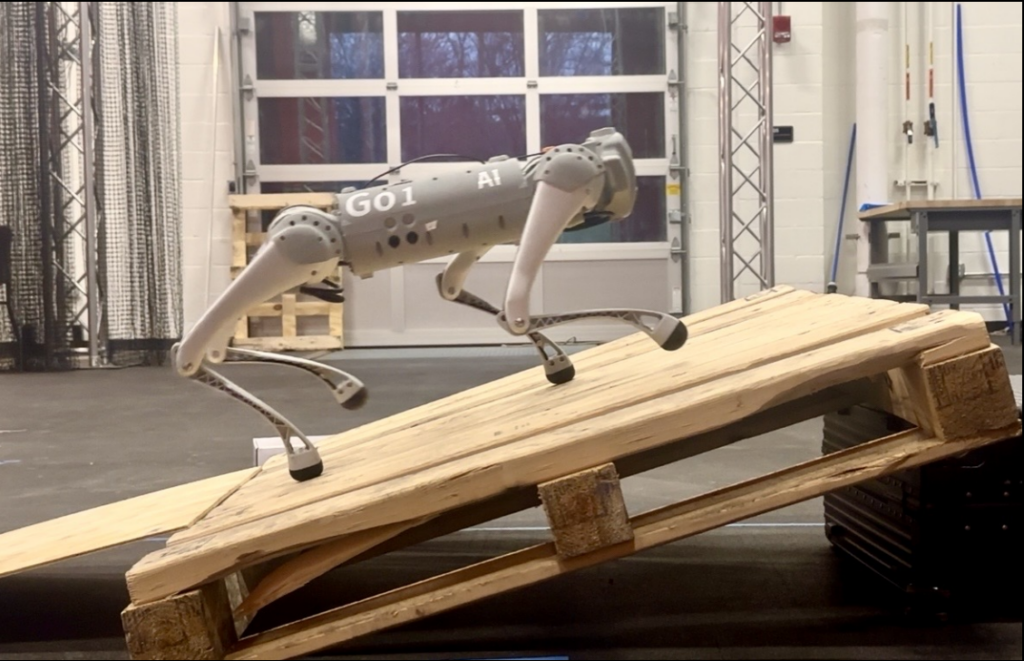
“Towards Torque-Driven Reinforcement Learning for Quadruped Locomotion,”
(SII 2026)
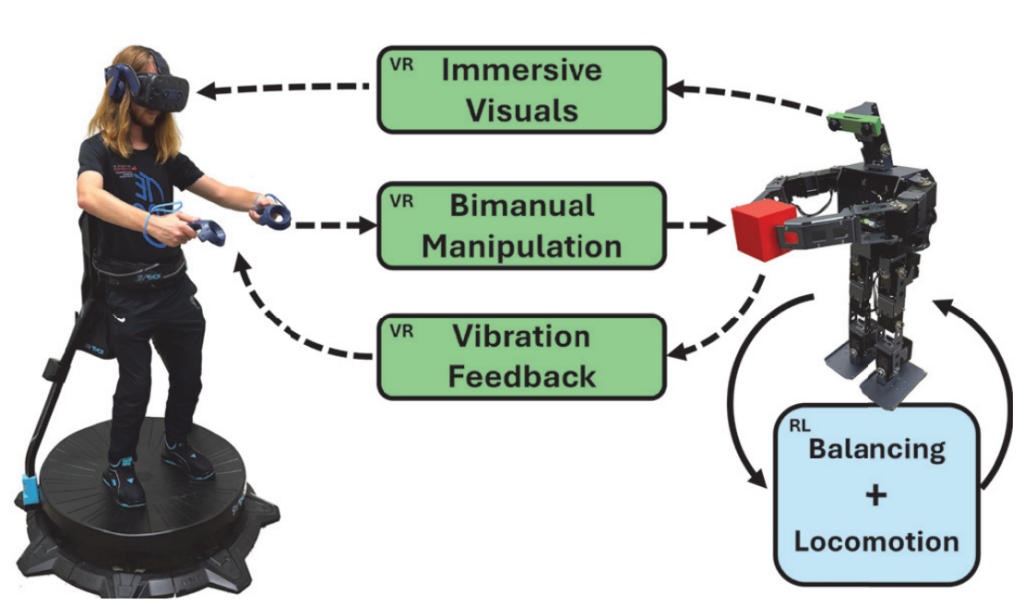
“Towards Miniature Humanoid Tele-Loco-Manipulation Using Virtual Reality and Reinforcement Learning,”
(Humanoids 2025)
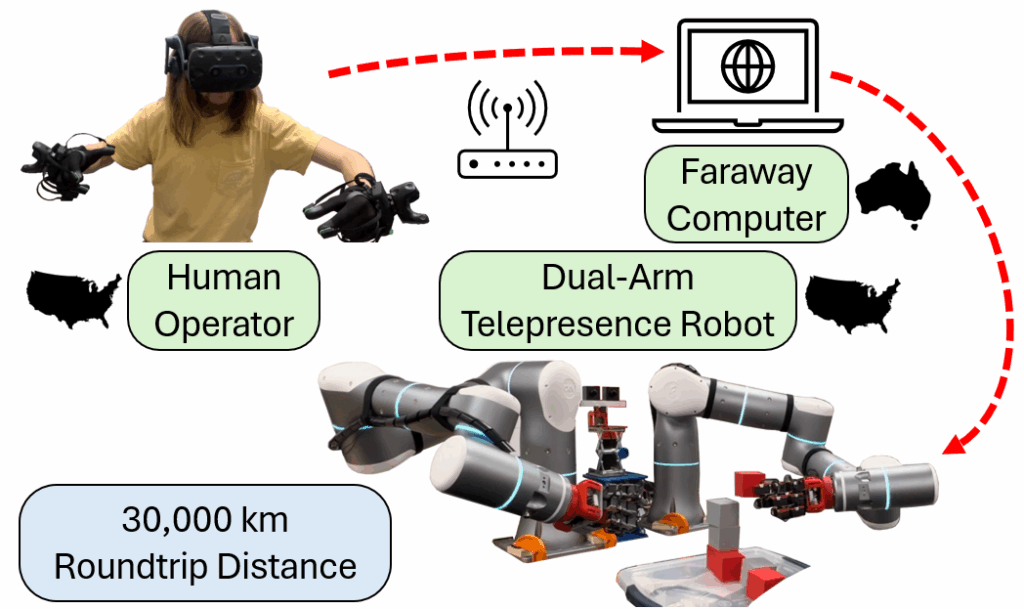
“A Virtual Reality Framework for Safe Global Bimanual Telepresence,”
(CASE 2025)
“Isaac Sim-to-Real: Reinforcement Learning based Locomotion for Quadrupeds,”
“Humans and Robots, Hand-in-Hand: Using Bilateral Telepresence to turn Robotic Hands into Wearable Haptic Exoskeletons,”
(UR 2025)
“Introducing H4ND: Hyper-resilient, 4-Fingered, Nimble, Dexterous Anthropomorphic Robot Hand Optimized for Research,” (UR 2024)
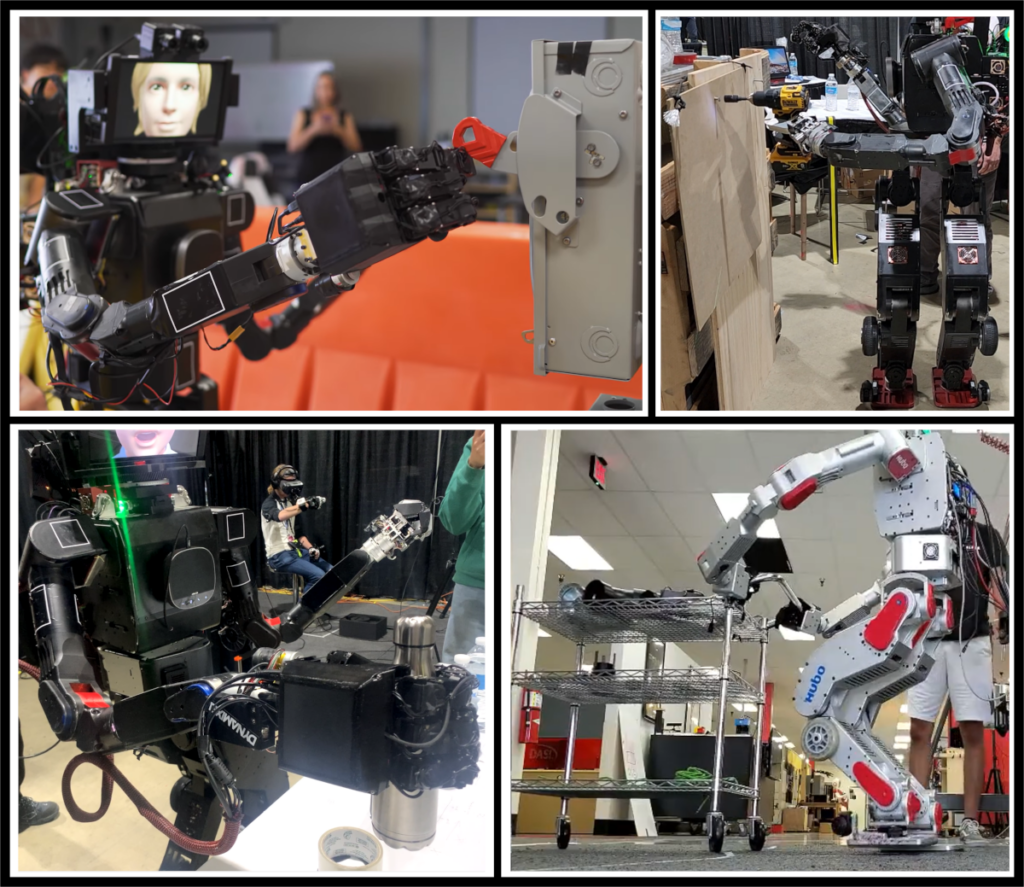
“ART: Avatar Robotics Telepresence—the future of humanoid material handling loco-manipulation.” (Jrnl of Intel Serv Robotics 2024)
“Biomimetic Real-Time Multimodal Tactile Perception and Haptics for Telepresence Humanoids,” (ICAR 2023)
“Real-Time Joint Trajectory Optimization and Predictive Safety Filtering for Telepresence Avatar Robotics,” (ICAR 2023)